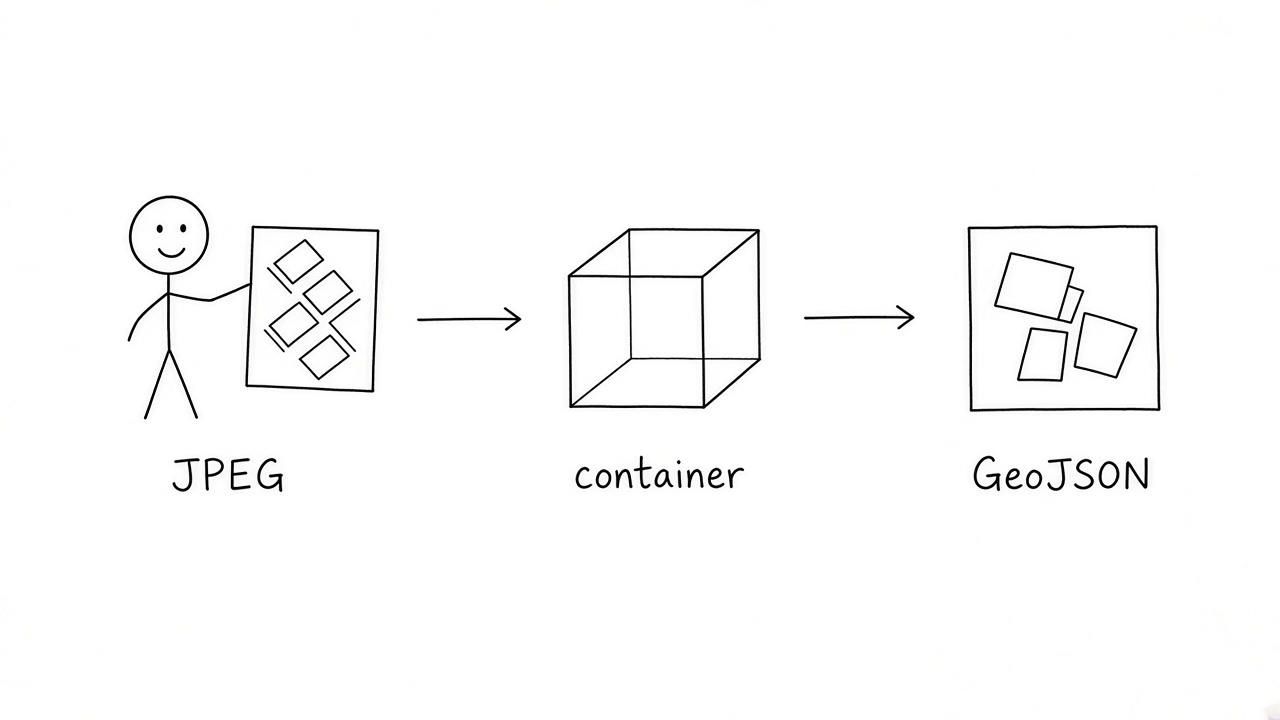
I wanted a tile to go in and polygons to come out, the way a GIS service already expects.
oriented-det ships that as a container: deploy/example/. You bake a checkpoint, docker build, and POST a JPEG. GeoJSON comes back. A large scene is tiled inside the image.
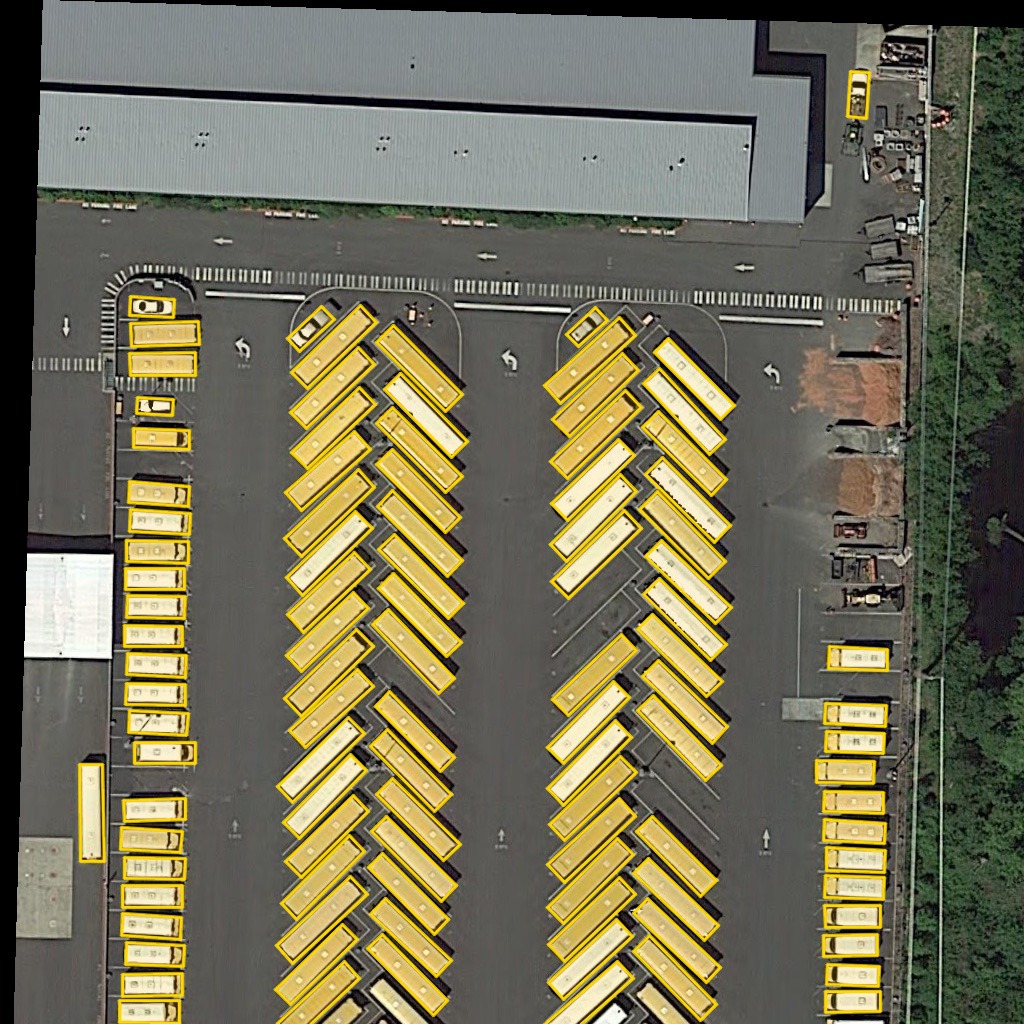
I tried it with Oriented R-CNN on the bus-lot demo, at score 0.55. 100 boxes came back — 95 large vehicles and 5 small ones. It is the same picture the command line has been drawing since June, now as polygons a map can store.
The Dockerfile and the request are below.
What the container is Link to heading
deploy/example/Dockerfile starts from nvidia/cuda:12.1.0-runtime-ubuntu22.04, installs torch/vision cu121, then oriented-det and a small Sanic app. Non-root user 10001. Healthcheck hits /api/v1/health. Port 8080.
| Verb | Path | Role |
|---|---|---|
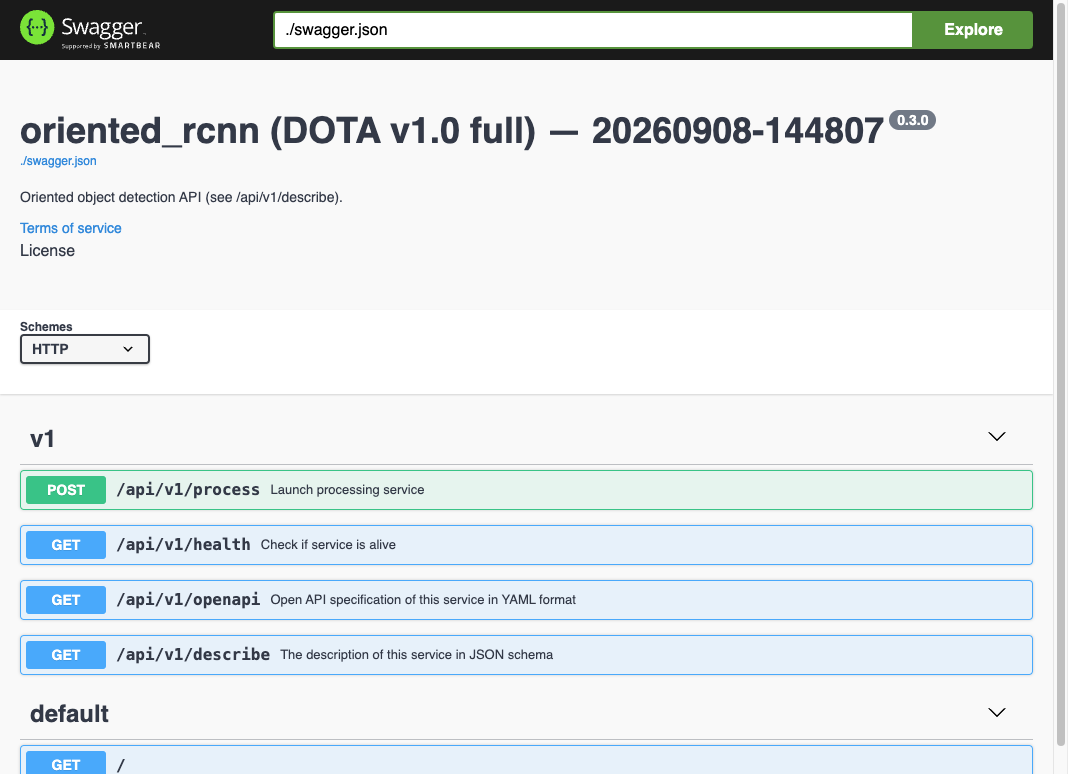
GET | /api/v1/health | liveness (OK) |
GET | /api/v1/describe | class list + metadata (description.json) |
GET | /api/v1/openapi | Tile Geo Process YAML |
POST | /api/v1/process | {resolution, tiles[]} → FeatureCollection |
GET | /swagger/ | live OpenAPI UI |
resolution is meters per pixel. It does not change the detector; it scales length / width on each feature into meters. tiles is a base64 JPEG or PNG array; the example runs the first tile.
One request at a time. A second POST while inference is running returns 429.
Bake a checkpoint Link to heading
Weights and config.json are not in git. Copy a Hub sidecar (resolved config) and its .pth, then generate description.json so /describe and Swagger get a title:
odet pretrained download oriented_rcnn_dota_le90_1x

mkdir -p deploy/example/app/weights
cp pretrained/oriented_rcnn_*_dota_le90_1x*.json deploy/example/app/config.json
cp pretrained/oriented_rcnn_*_dota_le90_1x*.pth  deploy/example/app/weights/model.pth

python deploy/scripts/generate_description.py \
  --config deploy/example/app/config.json \
  --out deploy/example/app/description.json \
  --deploy-version 0.3.1
After your own train, copy runs/<family>/<ts>/config.json and checkpoints/checkpoint_best.pth instead. Same two filenames inside deploy/example/app/.
Build from the repo root (build context is the library, not the app/ folder):
docker build -f deploy/example/Dockerfile -t odet-example:latest .
docker run --rm -p 8080:8080 --gpus all odet-example:latest
--gpus all is the NVIDIA path this image is for. The Python falls back to CPU if CUDA is missing; the base image is still a CUDA runtime, so a Mac or CPU-only host is a smoke test, not the production shape.
curl -fsS http://127.0.0.1:8080/api/v1/health   # OK
open http://127.0.0.1:8080/swagger/
POST a tile Link to heading
import base64, json, urllib.request
from pathlib import Path

tile = base64.b64encode(Path("demo/demo.jpg").read_bytes()).decode()
req = urllib.request.Request(
    "http://127.0.0.1:8080/api/v1/process",
    data=json.dumps({"resolution": 0.5, "tiles": [tile]}).encode(),
    headers={"Content-Type": "application/json"},
)
fc = json.loads(urllib.request.urlopen(req).read())
print(len(fc["features"]), fc["features"][0]["properties"])
On this Hub checkpoint that printed 100 and:
{
  "category": "large-vehicle",
  "confidence": 0.9995,
  "length": 48.22,
  "width": 11.24
}
length / width are meters at resolution=0.5. Geometry is an image-pixel polygon, closed ring, Polygon in a FeatureCollection.
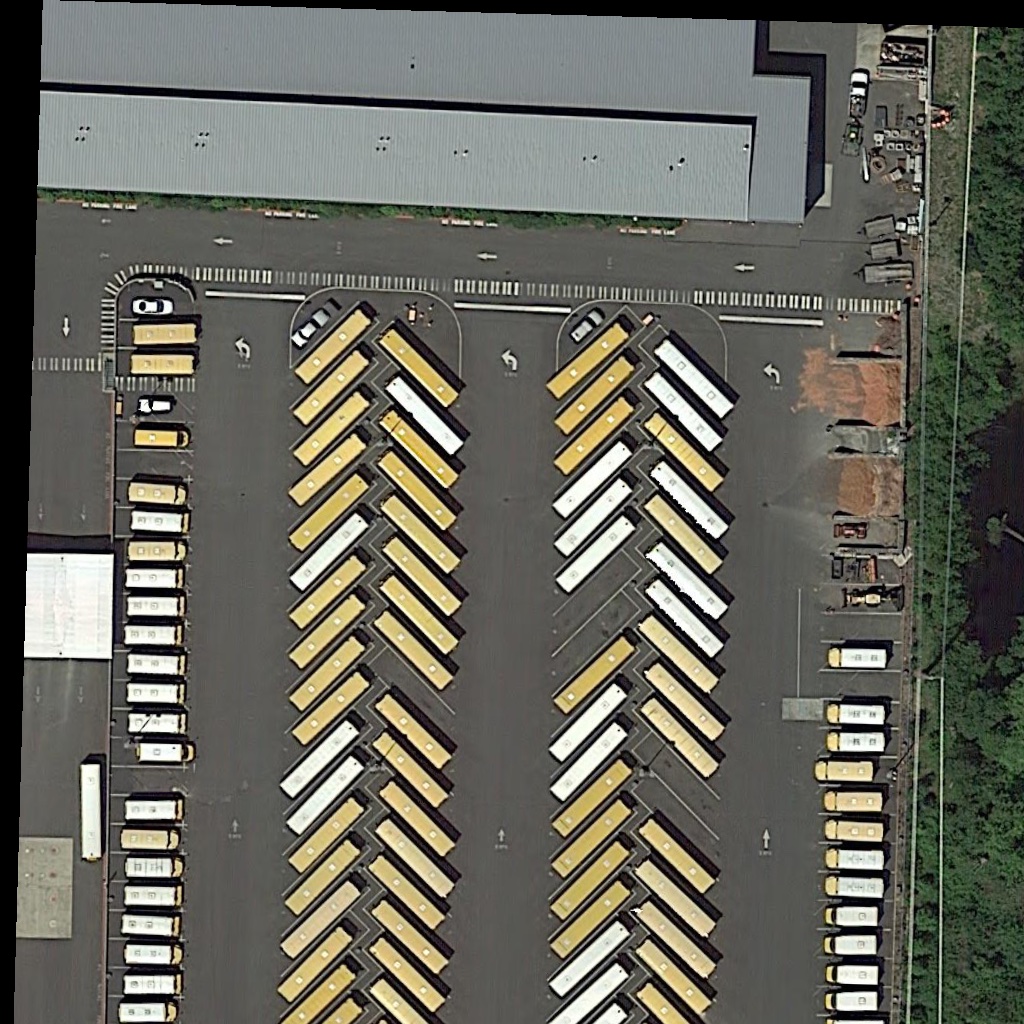
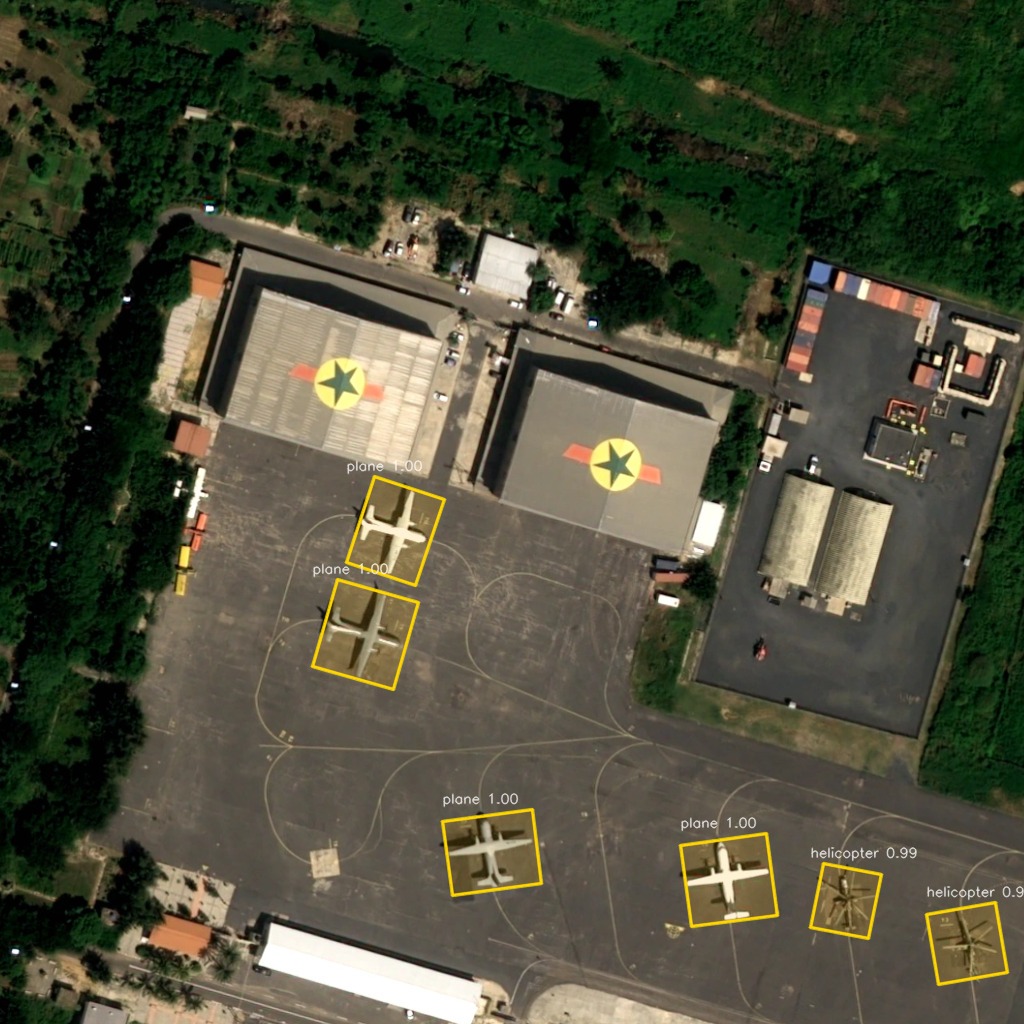
The same publish on the Pleiades Neo export tile (export/demo/planes_pleiades_neo.jpg, resolution=0.3) returned 6 boxes: 4 plane, 2 helicopter. That is the tile the ONNX post reuses.
What production.* does in the container
Link to heading
Deploy does not use the eval-val floor of 0.05. InferenceEngine reads config.production.* after apply_inference_config_to_model:
| Knob | This Hub slug | Effect |
|---|---|---|
score_threshold | 0.55 | post-decode keep |
final_nms_iou_threshold | 0.1 | merge NMS |
stick_to_model_canvas | true | 1024×1024; larger images tile |
overlap_pixels | 200 | sliding-window overlap |
ignore_margin_pixels | 0 | full-image centroid edge filter (0 = off) |
demo.jpg is already 1024, so this run was one forward. demo/large.jpg (1299×1904) would slide — six windows at the default 200 px overlap, same tile as the sliding-window note. That path stays in this container. It is out of the ONNX graph in v0.3.
DOTA deploy floors are eval-val global F1 − 0.05 (Oriented R-CNN 0.55, Faster R-CNN 0.6, FCOS 0.2, RetinaNet OBB 0.25). Do not copy 0.55 onto FCOS.
Links Link to heading
- docs — Docker deploy ·
deploy/example/README.md - v0.3 release note
- Previous: HRSID · v0.3
- Next: ONNX export (8 Oct)